AF3
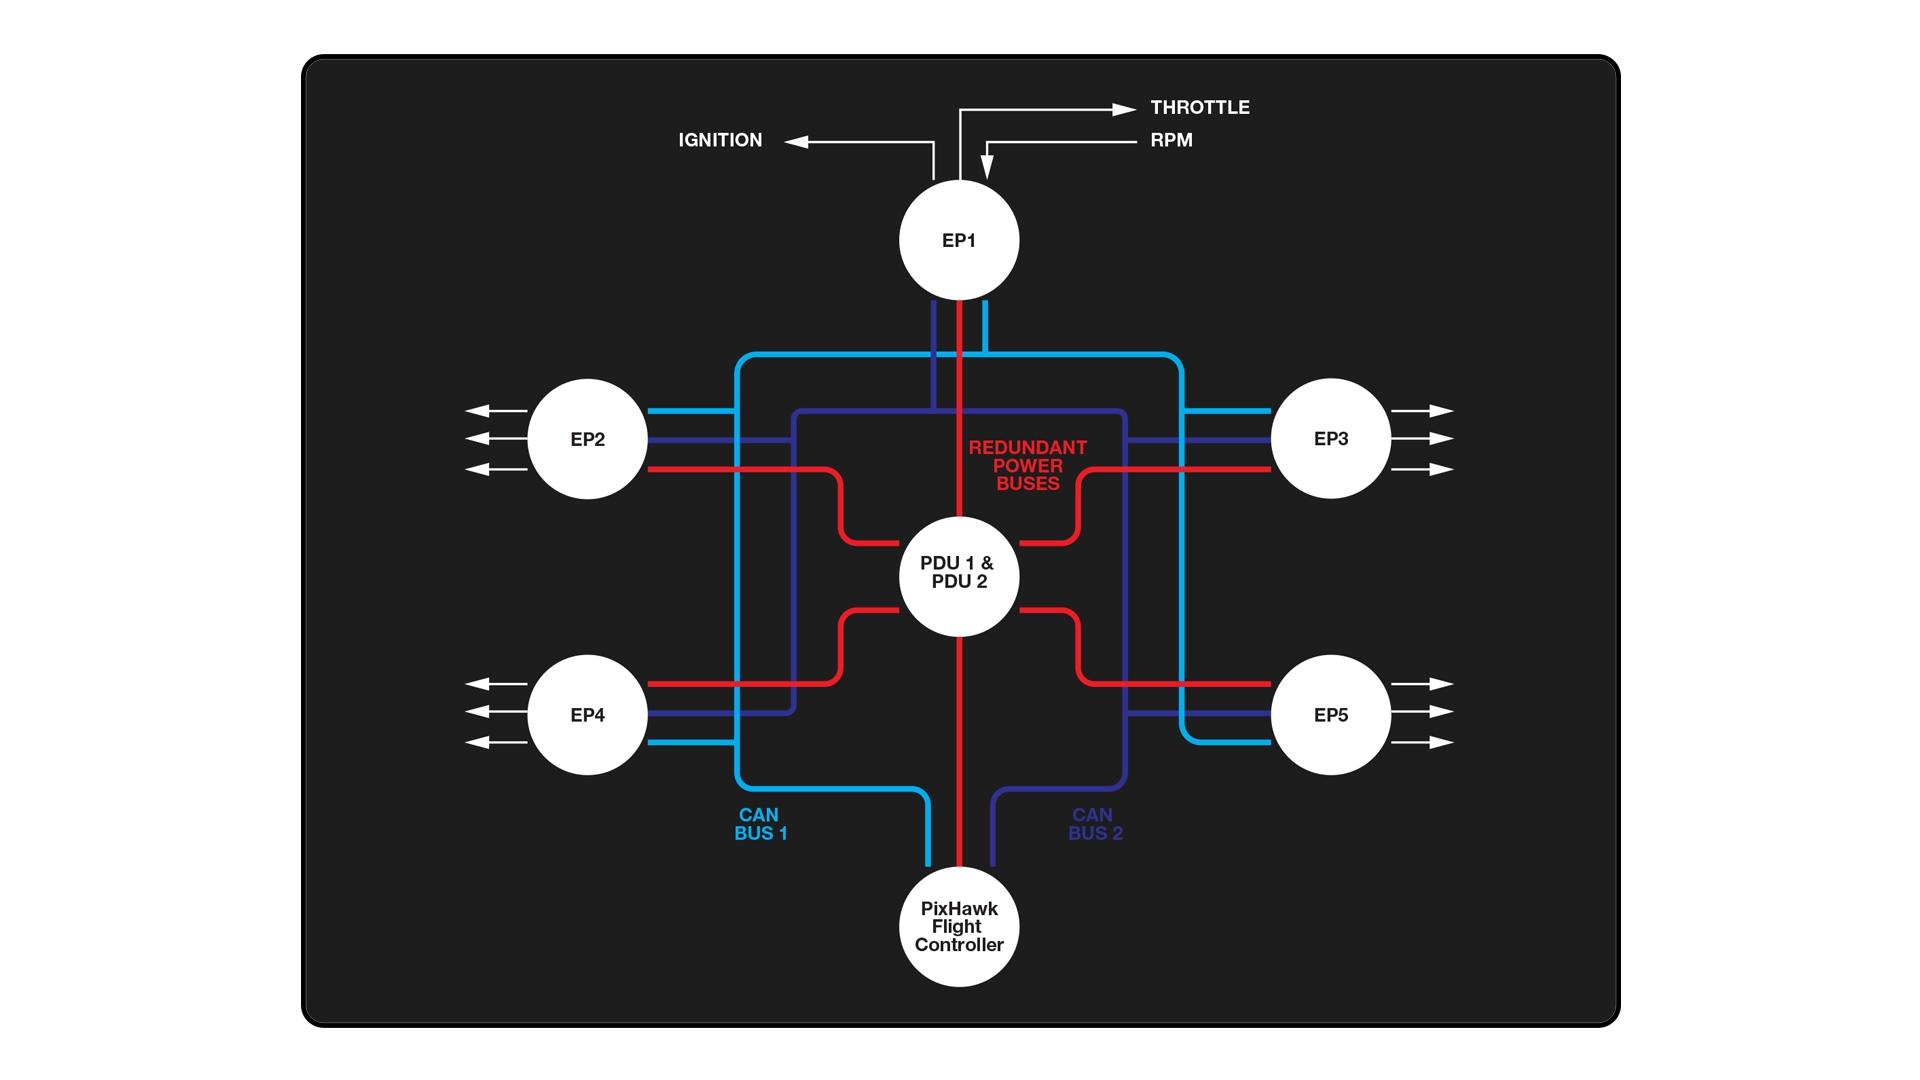
The AF3 Redundant Flight System is a flight‑control architecture that offers high reliability through isolated CAN buses and distributed arbitration across up to three controllers.
- Origin
- Collected automatically
- Source
- Manufacturer page (rfdesign.com.au) +1 more
- Retrieved
- 25 Sept 2026
- Last checked
- 25 Sept 2026
- Report
- Report an error or request removal
As an introductory model of RFDesign’s flight-control family, the AF1 integrates multiple redundancy solutions including up to three isolated CAN buses. It supports distributed arbitration across up to three independent flight controllers, enabling seamless failover in case of subsystem failures. The system includes power‑failure isolation and alternative power flow, as well as a virtual flight controller interface that simplifies operator training.
Compliance/certification
- NDAA compliant
- Yes
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Low · 60%
Collected automatically from the source; not reviewed yet.
General
- Mon – Fri
- 8am – 5pm
Redundancy
- CAN bus count
- 3
- Flight controller count
- 3
Protection
- Power protection
- Yes
- Failure isolation
- Yes
Interface
- Operator interface simplicity
- Virtual single controller
Design
- Modular design
- Yes
Values are normalised to SI-style units. Open a value's source marker for provenance and confidence. Additional specifications are shown as published by the source, without unit conversion. Spotted an error? Report it to us, tell the manufacturer or claim this listing.
- Software & SDKs
- Firmware
Ask RFDesign about AF3
1S Brushless FC
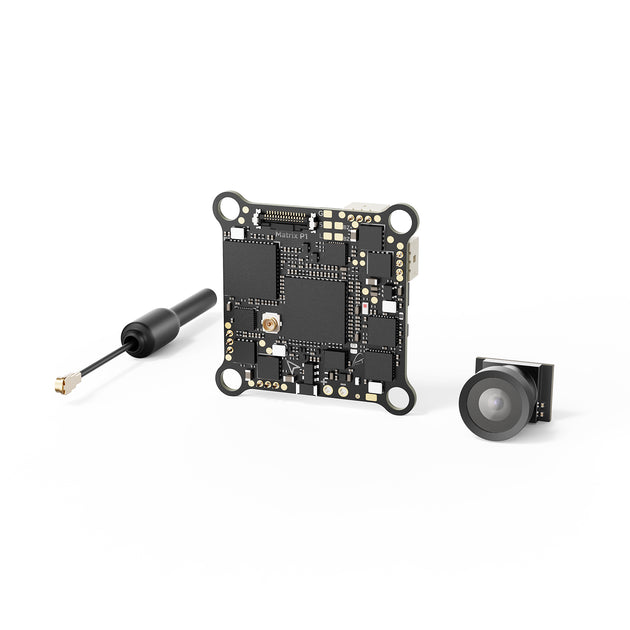
A micro flight controller designed for 1S brushless setups.

Agam Autopilot V6X-RT
The Agam Autopilot V6X‑RT is a complete flight controller package that combines dual IMUs, barometer, magnetometer and storage for UAVs.
Agam Drone Electronics Kit
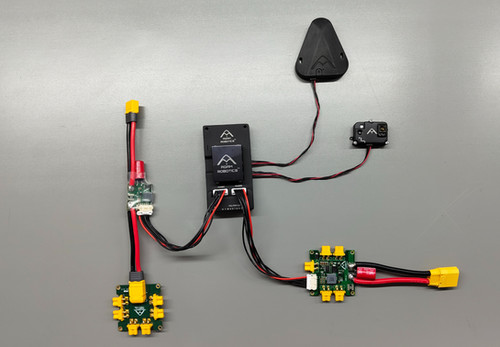
An electronics bundle for UAVs that includes an Agam Autopilot v6X‑RT, a FloRange Sensor, cables, and a USB cord.

AuterionOS
AuterionOS is a vendor‑independent operating system that runs onboard interconnected robots, providing autonomous flight control, real‑time communication and cloud‑based fleet management.