DEXI
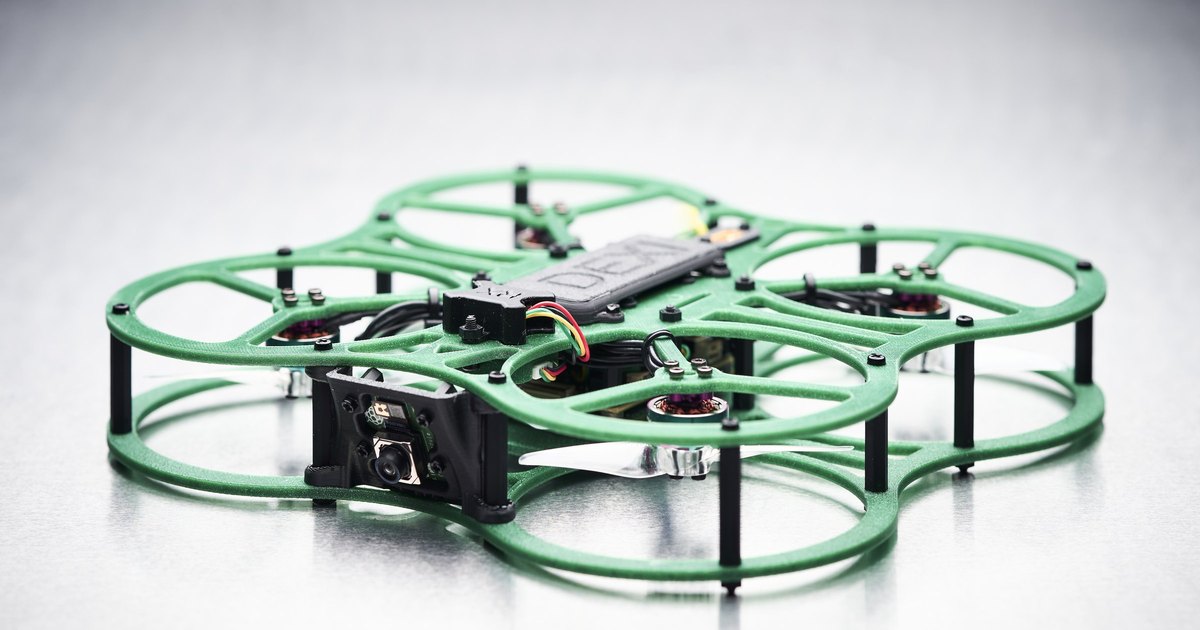
A compact indoor multirotor drone designed for classroom STEM learning with an open ROS 2 and PX4 flight stack.
- Origin
- Collected automatically
- Source
- Manufacturer page (droneblocks.io) +1 more
- Retrieved
- 25 Sept 2026
- Last checked
- 25 Sept 2026
- Report
- Report an error or request removal
The DEXI‑3 is a 3" carbon‑fiber or 3D‑printed airframe equipped with four 4680 KV brushless motors, a Raspberry Pi CM5 companion computer, and a Raspberry Pi Camera Module 3. It uses an optical‑flow sensor and a downward time‑of‑flight range finder for GPS‑free indoor hovering. The platform runs the PX4 autopilot (v1.17) linked to ROS 2 Jazzy via a MicroDDS bridge, enabling custom Python or C++ code, vision algorithms such as YOLOv8‑nano and AprilTag detection, and full ground‑control integration with QGroundControl over MAVLink.
General
- Propulsion
- Electric
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Medium · 80%
Collected automatically from the source; not reviewed yet.
Performance
- Endurance
- 10min
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Medium · 80%
Collected automatically from the source; not reviewed yet.
Payload
- Sensor
- IMX708, 12 MP
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Medium · 85%
Collected automatically from the source; not reviewed yet.
Communications
- Interfaces
- I²C (2×), UART (2×), GPIO, Ethernet 10/100, USB‑C, Micro HDMI, Fan PWM + tach
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Medium · 75%
Collected automatically from the source; not reviewed yet.
Navigation
- GNSS-denied navigation
- Yes
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Medium · 75%
Collected automatically from the source; not reviewed yet.
Power
- Battery / fuel
- 7–28 V input → 5 V @ 4 A buck regulator (TPSM86638)
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Medium · 75%
Collected automatically from the source; not reviewed yet.
Software/autonomy
- Autonomy features
- Waypoint missions
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Medium · 75%
Collected automatically from the source; not reviewed yet.
- Ground control software
- QGroundControl over MAVLink Router
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Medium · 75%
Collected automatically from the source; not reviewed yet.
Compliance/certification
- NDAA compliant
- Yes
Source
- Source
- Manufacturer page
- Retrieved
- 25 Sept 2026
- Last reviewed
- 25 Sept 2026
- Confidence
- Low · 60%
Collected automatically from the source; not reviewed yet.
The fine print, on demand
- PX4 ↔ ROS 2
- MicroDDS bridge, PX4 uORB topics published into the ROS 2 graph on the CM5.
- PX4 ↔ QGroundControl
- MAVLink Router on the CM5.
- Pilot ↔ Drone
- ELRS 2.4 GHz, Nano RX.
- Developer ↔ Drone
- Wi-Fi to the CM5, SSH, ROS 2 networking, file deploy.
- Frame
- 3″ carbon fiber (Developer Kit); 3D-printed on the Flight Kit, carbon fiber upgrade available
- Flight Controller / ESC
- DroneBlocks H743-based FC w/ integrated ESC, PX4 1.17
- Companion
- Raspberry Pi CM5 on DroneBlocks custom carrier board
- Flow & Distance
- Optical flow + downward ToF range finder
- TX / RX
- ELRS TX + ELRS Nano RX
- Mounts
- M2.5 standoffs, 3.0 mm
- FC / ESC
- DroneBlocks H743, integrated ESC
- Firmware
- PX4 1.17, custom DroneBlocks branch
- Optical flow
- Downward
- ToF range finder
- Downward
- Module
- Raspberry Pi CM5
- Carrier
- DroneBlocks Pi Carrier Board
- Wireless
- Wi-Fi + Bluetooth
- Power
- 7–28 V → 5 V @ 4 A buck (TPSM86638)
- I²C
- 2× JST-GH, 4.7 kΩ pull-ups, ESD
- UART
- 2× JST-GH, ESD
- Addressable LED
- GPIO JST-GH
- Ethernet
- 10/100 JST-GH
- USB-C
- USB 2.0
- Display
- 1× Micro HDMI
- Fan
- 4-pin JST-SH, PWM + tach
- Default ROS 2 stream
- 640×480 @ 30 FPS MJPEG via camera_ros/libcamera
- Configurable
- Up to full sensor resolution
- Object detection
- YOLOv8-nano via dexi_yolo
- Inference
- ONNX Runtime, CPU inference on CM5
- Fiducials
- AprilTag CPU detector
- Transmitter
- ELRS handheld TX, RadioMaster-class
- Receiver
- ELRS Nano RX
- Band
- 2.4 GHz
- Charger
- Classroom-safe
- OS
- DEXI OS
- Middleware
- ROS 2 Jazzy
- Autopilot
- PX4 1.17
- Programming
- DroneBlocks, Python, ROS 2, custom
- Ground station
- QGroundControl over MAVLink Router
- ROS 2
- the full stack on the CM5: topics, services, and actions.
Physical dimensions
- Airframe size
- "3" carbon‑fiber (Developer Kit) / 3D‑printed (Flight Kit)
Powertrain
- Motors
- 4 × 4680 KV brushless
- Propellers
- 4 × 3018 tri‑blade
Onboard electronics
- Flight controller
- DroneBlocks H743 FC + integrated ESC, PX4 1.17
- Companion computer
- Raspberry Pi CM5 on custom carrier board
Sensors
- Camera
- Raspberry Pi Camera Module 3 (IMX708, 12 MP)
- Vision system
- Optical flow + downward time‑of‑flight range finder
Imaging
- Camera resolution
- 640×480 @ 30 fps MJPEG (configurable to full sensor resolution)
Wireless
- Transmission
- ELRS handheld TX + ELRS Nano RX, 2.4 GHz
- Additional wireless
- Wi‑Fi & Bluetooth to CM5 (SSH, ROS 2 networking)
Power source
- Battery
- 3S LiPo, 11.1 V, XT30 connector
Data storage
- Storage
- 64 GB microSD, eMMC + microSD
Lighting
- LEDs
- Addressable LED strip
Software
- Operating system
- DEXI OS (Raspberry Pi OS build with PX4 link, ROS 2 bridge)
Values are normalised to SI-style units. Open a value's source marker for provenance and confidence. Additional specifications are shown as published by the source, without unit conversion. Spotted an error? Report it to us, tell the manufacturer or claim this listing.
- Firmware
- PX4 1.17
- Software & SDKs
- ROS 2 JazzyQGroundControl
Ask DroneBlocks about DEXI